9.3 Residual Smoothing 残差光顺[cfd-9-3]
显式多级时间推进格式(6.1.1和6.1.2小节)的最大CFL数及其收敛特性,可以通过优化各级系数来加以改变[5]–[7]。Jameson和Baker[8]提出了残差光顺(residual smoothing)技术,目的是赋予显式格式以隐式特性,从而提高最大允许CFL数。残差光顺的另一个目的,是对残差高频误差分量更好的阻尼。这对于成功应用多重网格方法尤为重要。en
The maximum CFL number and the convergence properties of the explicit multistage time-stepping scheme (Subsections 6.1.1 and 6.1.2) can be influenced by optimising the stage coefficients [5]--[7]. Jameson and Baker [8] introduced the residual smoothing technique with the aim to lend the explicit scheme an implicit character and hence to increase the maximum allowable CFL number. A further purpose of the residual smoothing is a better damping of the high-frequency error components of the residual. This is of particular importance for a successful application of the multigrid method.
残差光顺可以分别以显式、隐式或混合的方式实现[9]、[10]。残差光顺通常在显式时间推进格式(式(6.5)、(6.7))的每一级中应用。在解\(\vec{W}^{(k)}\)更新之前,先前算得的残差\(\vec{R}^{(k)}\)被光顺后的残差\(\vec{R}^{*}\)所取代。下面,我们将讨论流行的隐式残差光顺(Implicit Residual Smoothing,IRS)在结构网格以及非结构网格上的实现。en
The residual smoothing can be implemented in explicit, implicit or in mixed manner [9], [10], respectively. The residual smoothing is usually applied in each stage of the explicit time-stepping scheme (Eqs. (6.5), (6.7)). The previously computed residuals \(\vec{R}^{(k)}\) are replaced by the smoothed residuals \(\vec{R}^{*}\) before the solution \(\vec{W}^{(k)}\) is updated. In the following, we shall discuss the implementation of the popular Implicit Residual Smoothing (IRS) on structured as well as on unstructured grids.
9.3.1 Central IRS on Structured Grids 结构网格上的中心IRS[cfd-9-3-1]
隐式残差光顺的标准形式在三维情形下为en
The standard formulation of the implicit residual smoothing reads in 3D
其中\(\vec{R}^{*}_{I,J,K}\)、\(\vec{R}^{**}_{I,J,K}\)和\(\vec{R}^{***}_{I,J,K}\)分别表示\(I\)、\(J\)、\(K\)方向上光顺后的残差。参数\(\epsilon^I\)、\(\epsilon^J\)和\(\epsilon^K\)表示三个计算坐标方向上的光顺系数。式(9.5)中的隐式算子类似于二阶中心差分,因此称为中心隐式残差光顺(Central Implicit Residual Smoothing,CIRS)。式(9.5)中的隐式方程组用求三对角矩阵之逆的Thomas算法求解。en
where \(\vec{R}^{*}_{I,J,K}\), \(\vec{R}^{**}_{I,J,K}\), and \(\vec{R}^{***}_{I,J,K}\) denote the smoothed residuals in \(I\)-, \(J\)-, and \(K\)-direction, respectively. The parameters \(\epsilon^I\), \(\epsilon^J\), and \(\epsilon^K\) stand for the smoothing coefficients in the three computational coordinates. The implicit operator in Eq. (9.5) resembles second-order central difference. The term Central Implicit Residual Smoothing (CIRS) is therefore used. The implicit system in Eq. (9.5) is solved by the Thomas algorithm for the inversion of tridiagonal matrices.
光顺系数通常定义为对流通量雅可比矩阵谱半径的函数[11]。其目的是在每个坐标方向上只施加为保持稳定性与良好误差阻尼所必需的光顺量。文献[12]针对二维情形给出了一个合适的公式en
The smoothing coefficients are usually defined as functions of spectral radii of the convective flux Jacobians [11]. The purpose is to apply only as much smoothing in each coordinate direction as it is necessary for stability and good error damping. A suitable formula for 2D was suggested in [12]
这里,\(\sigma^{*}/\sigma\)表示光顺格式与未光顺格式的CFL数之比。变量\(r\)表示对流通量谱半径之比(式(4.53)),即\(r = \hat{\Lambda}_c^{J}/\hat{\Lambda}_c^{I}\)。参数\(\Psi \approx 0.125\)保证光顺操作的线性稳定性。en
Here, \(\sigma^{*}/\sigma\) denotes the ratio of the CFL numbers of the smoothed and unsmoothed scheme. The variable \(r\) stands for the ratio of the convective spectral radii (Eq. (4.53)), i.e., \(r = \hat{\Lambda}_c^{J}/\hat{\Lambda}_c^{I}\). The parameter \(\Psi \approx 0.125\) ensures linear stability of the smoothing operation.
其中en
where
等等。参数\(\Psi\)的典型取值为0.0625。en
etc. The typical value of the parameter \(\Psi\) is 0.0625.
CFL数之比\(\sigma^{*}/\sigma\)的最大值取决于光顺系数的取值以及空间离散格式的类型。对于中心格式(4.3.1小节),该比值由下式给出en
The maximum of the ratio of the CFL numbers \(\sigma^{*}/\sigma\) depends on the value of the smoothing coefficient and on the type of the spatial discretisation scheme. In the case of the central scheme (Subsection 4.3.1), the ratio is given by
实际中,可以达到\(\sigma^{*}/\sigma \approx 2\)(\(\epsilon = 0.8\))。更高的比值会削弱时间推进格式的阻尼能力。对于上风空间离散,不存在像式(9.8)这样简单的条件,因为\(\sigma^{*}/\sigma\)的最大值还与各级系数有关。但通常,无黏流动的CFL数(见表6.1和表6.2)可以提高约两倍,黏性流动(采用表6.2中的混合格式)最多可提高约五倍。图9.2和图9.3展示了中心IRS对结构网格上无黏流动与黏性流动收敛的影响。比较按CPU时间进行,以计入IRS带来的额外计算量。可以看到,求解时间可以显著缩短,对黏性流动尤其明显。不过,当IRS与多重网格(9.4节)联合使用时,还能获得更大的节省。en
In practice, value of \(\sigma^{*}/\sigma \approx 2\) can be reached (\(\epsilon = 0.8\)). Higher ratios reduce the damping of the time-stepping scheme. There is no such simple condition like (9.8) for the upwind spatial discretisation since the maximum of \(\sigma^{*}/\sigma\) depends also on the stage coefficients. But normally, the CFL number (see Tables 6.1 and 6.2) can be raised by about factor two for inviscid and up to factor five for viscous flows (using the hybrid scheme from Table 6.2). Figures 9.2 and 9.3 demonstrate the effect of the central IRS on the convergence for an inviscid and viscous flow on structured grids. The comparison is done in terms of the CPU time, in order to account for the additional numerical effort due to the IRS. As we can see, the solution time can be significantly reduced especially for a viscous flow. Even larger savings can be however realised when the IRS is employed together with multigrid (Section 9.4).
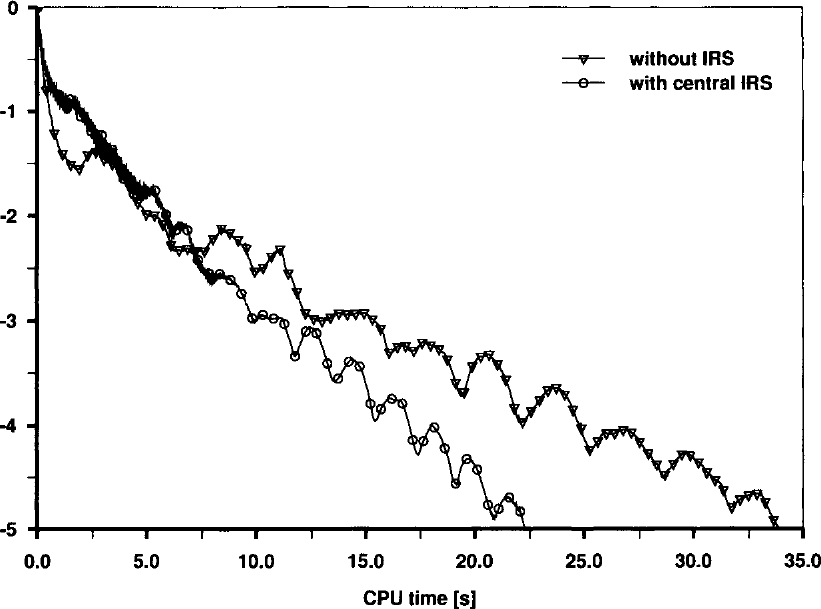
图9.2:结构网格上无黏跨声速流动有/无IRS时收敛历史的比较。纵轴:log(res)(残差的对数);横轴:CPU时间(CPU time [s]);图例:without IRS——无IRS;with central IRS——有中心IRS。
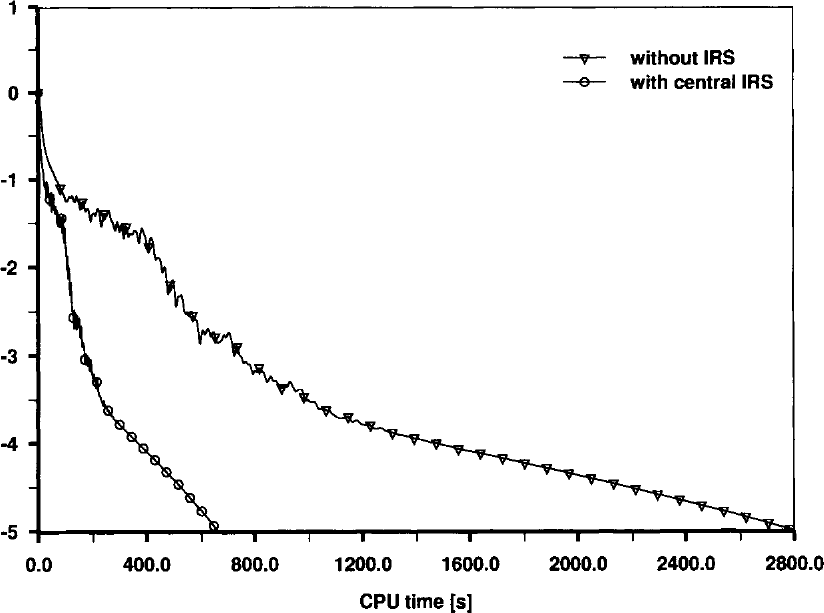
图9.3:结构网格上黏性亚声速流动有/无IRS时收敛历史的比较。纵轴:log(res)(残差的对数);横轴:CPU时间(CPU time [s]);图例:without IRS——无IRS;with central IRS——有中心IRS。
式(6.18)中由黏性谱半径\(\hat{\Lambda}_v\)造成的时间步长限制,可以借助隐式残差光顺来补偿。最大时间步长按式(6.14)计算,但不包含\(\hat{\Lambda}_v\)。在黏性谱半径占主导的流动区域,用较大的系数\(\epsilon^I\)、\(\epsilon^J\)、\(\epsilon^K\)进行光顺。基于黏性谱半径的光顺系数可由文献[12]、[13]中的公式计算en
The limitation of the time step due to the viscous spectral radius \(\hat{\Lambda}_v\) in Eq. (6.18) can be offset with the aid of the implicit residual smoothing. The maximum time step is calculated according to the formula (6.14) without \(\hat{\Lambda}_v\). In flow regions where the viscous spectral radius dominates, smoothing is carried out using higher coefficients \(\epsilon^I\), \(\epsilon^J\), \(\epsilon^K\). Smoothing coefficients based on the viscous spectral radii can be computed from [12], [13]
9.3.2 Central IRS on Unstructured Grids 非结构网格上的中心IRS[cfd-9-3-2]
在非结构网格上,CIRS通过把拉普拉斯算子(见式(5.24))作用于残差来实现。于是,控制体\(I\)内光顺后的残差\(\vec{R}^{*}_{I}\)由如下隐式关系得到[14]en
CIRS is implemented on unstructured grids by applying the Laplacian operator (see Eq. (5.24)) to the residual. Thus, the smoothed residual \(\vec{R}^{*}_{I}\) in a control volume \(I\) is obtained from the implicit relation [14]
求和遍及所有\(N_A\)个相邻控制体。关系式(9.10)用Jacobi迭代对\(\vec{R}^{*}_{I}\)求解。光顺系数的实用取值范围为\(0.5 \le \epsilon \le 0.8\)。采用这些\(\epsilon\)值,可以把CFL数(因而时间步长)提高二至五倍。由于矩阵对角占优,Jacobi迭代大约两步即收敛。en
The sum includes all \(N_A\) adjacent control volumes. The relation (9.10) is solved for \(\vec{R}^{*}_{I}\) using Jacobi iteration. Useful values of the smoothing coefficient are \(0.5 \le \epsilon \le 0.8\). With these values of \(\epsilon\) it is possible to increase the CFL number (and hence the time step) two to five times. Due to the diagonal dominance of the matrix, the Jacobi iteration converges in about two steps.
9.3.3 Upwind IRS on Structured Grids 结构网格上的上风IRS[cfd-9-3-3]
前面讨论的CIRS方法对亚声速和跨声速流动工作良好,在黏性占主导的区域也很有帮助。然而,与上风空间离散格式结合使用时,CIRS的误差阻尼特性较差。此外,经CIRS加速的多级格式在强激波情形下鲁棒性会下降。为此,人们发展了所谓的上风隐式残差光顺(Upwind Implicit Residual Smoothing,UIRS)方法[15]、[16],它特别适合高马赫数流动。en
The previously discussed CIRS method works satisfactorily for subsonic and transonic flows. It is also helpful in viscous dominated regions. However, CIRS exhibits poor error-damping characteristics in conjunction with upwind spatial discretisation schemes. Furthermore, the robustness of a multistage scheme accelerated by CIRS suffers in the case of strong shocks. Therefore, the so-called Upwind Implicit Residual Smoothing (UIRS) method was developed [15], [16], which is particularly suited for high Mach-number flows.
与CIRS不同,UIRS方法考虑了对流特征值\(\bar{\Lambda}_c\)的符号。其思想是只在欧拉方程特征线的方向上光顺残差(即\(dx/dt = \mathrm{const.} = \Lambda_c\))。这种做法可防止对上游残差产生非物理的影响。UIRS方法要求把残差变换到特征变量(参见附录A.11)。这样,残差向量的每个分量都可以按照相应特征值的符号独立地进行光顺。对于残差的第\(l\)个分量,一维情形下的隐式算子定义为[15]、[16]en
By contrast to CIRS, the UIRS methodology takes the sign of the convective eigenvalues \(\bar{\Lambda}_c\) into account. The idea is to smooth the residuals only in the direction of the characteristic of the Euler equations (i.e., \(dx/dt = \mathrm{const.} = \Lambda_c\)). This approach prevents unphysical influences on the upstream residuals. The UIRS method requires transformation of the residuals into the characteristic variables (cf. Appendix A.11). In this way, each component of the residual vector can be smoothed independently according to the sign of the corresponding eigenvalue. For the \(l\)-th component of the residual, the implicit operator is defined in 1D as [15], [16]
其中\(\vec{R}^{c}\)表示变换到特征变量后的残差,即en
where \(\vec{R}^{c}\) denotes the residual transformed into characteristic variables, i.e.,
光顺后的残差\(\vec{R}^{*}\)通过用Thomas算法求解一个三对角(若\(\Lambda_c^l\)不变号则为二对角)方程组而得到。随后,把残差\(\vec{R}^{*}\)变换回守恒变量,之后即可更新解。en
The smoothed residuals \(\vec{R}^{*}\) are obtained by the solution of a tridiagonal (bidiagonal if \(\Lambda_c^l\) does not change its sign) equation system using the Thomas algorithm. Afterwards, the residuals \(\vec{R}^{*}\) are transformed back into the conservative variables and the solution can be updated.
UIRS最理想的特性在于,它使多级格式具有非常好的阻尼特性,与上风空间离散格式结合时尤其如此。在光顺系数很大时,阻尼解误差的能力仍保持不变甚至有所提高。对一维欧拉方程已经证明,像\(\epsilon = 500\)和\(\sigma^{*} = 1000\)这样的取值可以得到稳定且非常快的显式多级格式[15]、[16](另见CD-ROM中的analysis/mstage)。然而,问题在于UIRS在多维情形下的实现。由于对流通量雅可比矩阵无法在所有坐标方向上同时对角化(见附录A.11),变换式(9.12)与光顺式(9.11)必须对每个计算坐标分别执行。坐标分裂的后果是最大光顺系数降为\(2 \le \epsilon \le 6\)。尽管如此,与CIRS相比,向定常态的收敛仍被大大加速[17]、[16]。在收敛速度与鲁棒性方面最大的改进,出现在与多重网格联合使用时[18]、[16]。en
analysis/mstage)。然而,问题在于UIRS在多维情形下的实现。由于对流通量雅可比矩阵无法在所有坐标方向上同时对角化(见附录A.11),变换式(9.12)与光顺式(9.11)必须对每个计算坐标分别执行。坐标分裂的后果是最大光顺系数降为\(2 \le \epsilon \le 6\)。尽管如此,与CIRS相比,向定常态的收敛仍被大大加速[17]、[16]。在收敛速度与鲁棒性方面最大的改进,出现在与多重网格联合使用时[18]、[16]。enThe most desirable feature of UIRS is that it leads to very favourable damping properties of the multistage scheme, particularly in connection with an upwind spatial discretisation. The ability to damp solution errors remains or even improves for high smoothing coefficients. It was demonstrated for 1-D Euler equations that values like \(\epsilon = 500\) and \(\sigma^{*} = 1000\) result in a stable and very fast explicit multistage scheme [15], [16] (see also in analysis/mstage on the CD-ROM). However, the problem is the implementation of UIRS in multiple dimensions. Since the convective flux Jacobians cannot be diagonalised simultaneously in all coordinate directions (see Appendix A.11), the transformation Eq. (9.12) and the smoothing Eq. (9.11) have to be carried out separately for each computational coordinate. The effect of the coordinate splitting is a reduced maximum smoothing coefficient to \(2 \le \epsilon \le 6\). Despite this, the convergence to the steady state is strongly accelerated as compared to CIRS [17], [16]. The largest improvements in terms of convergence speed and robustness occur in combination with multigrid [18], [16].
多维情形下的光顺系数按特征值进行缩放。例如在二维情形下,可以采用如下公式en
The smoothing coefficients in multiple dimensions are scaled by the eigenvalues. For example, in 2D the following formula can be employed
光顺格式的CFL数与系数\(\epsilon\)之间的关系为en
The relation between the CFL number of the smoothed scheme and the coefficient \(\epsilon\) reads
常数\(C\)取决于空间离散格式的类型。中心格式为\(C = 1\);一阶或二阶上风格式则为\(C = 2\)。en
The constant \(C\) depends on the kind of the spatial discretisation. In the case of the central scheme \(C = 1\). For the 1st- or 2nd-order upwind scheme the value is \(C = 2\).
为了避免变换到特征变量所需的计算量,有人提出了UIRS方法的简化版本[17]、[18]、[16]。按\(I\)方向写出即为en
In order to circumvent the numerical effort of the transformation to the characteristic variables, a simplified version of the UIRS method was suggested [17], [18], [16]. Written in the \(I\)-direction it reads
马赫数\(M\)基于投影到相应计算坐标方向(这里为\(I\))上的速度。由于运算量低,简化UIRS特别适合三维流动问题。文献[16]中证明,与CIRS相比,到达定常态所需的CPU时间可以减半(绕钝头圆柱的高超声速流动,\(M_\infty = 8\))。en
The Mach number \(M\) is based on velocity projected into the direction of the particular computational coordinate (here: \(I\)). Due to the low operation count, the simplified UIRS is especially suitable for 3-D flow problems. In Ref. [16] it was demonstrated that the CPU time needed to reach the steady state can be halved as compared to CIRS (hypersonic flow past a blunt cylinder, \(M_\infty = 8\)).