7.3 Large-Eddy Simulation 大涡模拟[cfd-7-3]
大涡模拟(Large-Eddy Simulation,LES)方法早在1963年就由Smagorinsky在气象学中(大气环流)采用[75]。LES的第一个工程应用(湍流槽道流)由Deardorff于1970年给出[76],其方法后来由Schumann加以扩展和改进[77]。20世纪80年代,湍流模拟的研究重心从LES转向直接数值模拟(DNS)。不过,一些重要工作仍在进行,例如Bardina等[78]、Moin和Kim[79]的工作。20世纪90年代初,对LES的兴趣重新回升[80]-[86]。如今,LES越来越多地用于具有工程意义的物理和几何复杂流动,例如燃烧室内的流动,实例可见文献[87]-[98]。这一趋势无疑得益于低成本、高能力计算机的普及。此外,如今的工程师也常常遇到标准湍流模型失效的流动问题;而且在某些情形下,平均流动频率与湍流脉动处于同一量级,此时时间平均失去意义,我们只能采用LES或DNS。en
The Large-Eddy Simulation (LES) methodology was employed already in 1963 by Smagorinsky in meteorology [75] (circulation of the atmosphere). The first engineering application of LES (turbulent channel flow) was presented by Deardorff in 1970 [76]. His method was later extended and improved by Schumann [77]. During 1980's, the research focus in the simulation of turbulence shifted from LES to Direct Numerical Simulation (DNS). However, some important work was still conducted, e.g., by Bardina et al. [78], Moin and Kim [79]. The interest in LES returned back at the beginning of 1990's [80]-[86]. Nowadays, LES is increasingly employed for physically and geometrically complex flows of engineering relevance like, e.g., in combustion chambers. Examples can be found in Refs. [87]-[98]. Certainly, this trend is supported by the availability of low-cost, highly powerful computers. Additionally, today's engineers are also often faced with flow problems, for which the standard turbulence models fail. Furthermore, in certain cases the mean flow frequencies are in the same order as the turbulent fluctuations. Hence, the time averaging looses its sense and we have to employ either LES or DNS.
LES基于这样一个观察:小的湍流结构比大涡在性质上更具普适性。因此,其思想是计算出大的、承载能量的结构对动量和能量输运的贡献,而把数值格式无法解析的小结构的影响建模。由于小尺度具有更均匀、更普适的性质,我们可以期望所谓的亚网格尺度(subgrid-scale)模型能够比RANS方程的湍流模型简单得多。en
LES is based on the observation that the small turbulent structures are more universal in character than the large eddies. Therefore, the idea is to compute the contributions of the large, energy-carrying structures to momentum and energy transfer and to model the effects of the small structures, which are not resolved by the numerical scheme. Due to the more homogeneous and universal character of the small scales, we may expect that the so called subgrid-scale models can be kept much simpler than the turbulence models for the RANS equations.
LES是控制方程的三维、随时间变化的解。与基于RANS方程的湍流建模相比,LES在流向(\(50 \le x^{+} \le 150\))和横向(\(15 \le z^{+} < 40\))也要求高网格分辨率。不过,LES的计算代价仍比DNS低得多。解析外层所需的网格点(单元)数正比于\(Re^{0.4}\)[99];在黏性底层内分辨率须按\(Re^{1.8}\)提高。因此,与DNS所需的\(Re^{9/4}\)相比,LES可以应用于至少高一个量级的雷诺数。为了进一步降低对网格分辨率的要求,LES可以与近似壁面模型联用(小节7.3.4),或与RANS模型耦合(小节7.3.5)。这两种途径都能以合理的计算代价对工程问题进行LES。en
LES represents a 3-D, time-dependent solution of the governing equations. In comparison to turbulence modelling based on the RANS equations, LES requires high grid resolution also in the streamwise (\(50 \le x^{+} \le 150\)) and in the cross-flow direction (\(15 \le z^{+} < 40\)). However, LES is computationally considerably cheaper than DNS. The number of grid points (cells) required to resolve the outer layer is proportional to \(Re^{0.4}\) [99]. The resolution has to be increased like \(Re^{1.8}\) in the viscous sublayer. Thus, if compared to \(Re^{9/4}\) required by DNS, LES can be applied at Reynolds numbers at least one order of magnitude higher. In order to further reduce the requirements on grid resolution, LES can be used in conjunction with approximate wall models (Subsection 7.3.4), or coupled with a RANS model (Subsection 7.3.5). Both approaches allow for LES of engineering problems at reasonable computational costs.
要准确解析高波数的湍流脉动,要求空间离散格式在波数空间具有相应的性质(参见例如[100]或[101])。因此谱方法常被采用。但谱方法只适用于具有(准)周期边界、几何形状简单的域。这正是有限差分和有限体积空间离散日益流行的原因。事实证明,中心差分格式比上风格式更合适,因为上风格式(无论精度阶数如何)由于其固有的数值阻尼,会在湍流谱的相当大一部分上耗散掉过多的能量[102]、[103]。关于谱方法与有限差分方法数值误差的讨论可参见[104]。en
An accurate resolution of high wave-number turbulent fluctuations requires spatial discretisation schemes with corresponding properties in the wave-number space (cf., e.g., [100] or [101]). Therefore, spectral methods are often employed. However, spectral methods are applicable only to geometrically simple domains with (quasi-)periodic boundaries. This is the reason why finite difference or finite volume spatial discretisations are becoming increasingly popular. Central differencing schemes proved to be more suitable than upwind schemes. The reason is that upwind schemes (regardless of the order of accuracy) dissipate too much energy over a significant portion of the turbulent spectra due to the inherent numerical damping [102], [103]. A discussion of numerical errors of spectral and finite difference methods can be found in [104].
在非结构网格上实现LES方法[105]-[109]是一个特别的挑战,但它能处理高度复杂的几何外形、运动边界以及动态网格自适应。其研究课题是在混合单元网格上发展数值高效的高阶空间离散。en
The implementation of LES methods on unstructured grids [105]-[109] represents a particular challenge. However, it allows for the treatment of highly complex geometries, moving boundaries or for dynamic grid adaptation. The research topic consists of the development of numerically efficient, high-order spatial discretisation on mixed-element grids.
LES的入门介绍可见文献[19]第269-336页,以及[110]-[112]或[90]。LES现状的综述见[113]。en
An introduction to LES can be found in Ref. [19], pp. 269-336, and in [110]-[112] or [90]. An overview of the present state of LES was given in [113].
7.3.1 Spatial Filtering 空间滤波[cfd-7-3-1]
LES基于空间滤波(spatial filtering)操作,它把任意流动变量\(U\)分解为滤波后(大尺度、可解析)的部分\(\overline{U}\)与亚滤波(不可解析)的部分\(U'\),即en
LES is based on a spatial filtering operation, which decomposes any flow variable \(U\) into a filtered (large-scale, resolved) part \(\overline{U}\) and into a sub-filter (unresolved) part \(U'\), i.e.,
空间中\(\vec{r}_0\)处的滤波变量定义为en
The filtered variable at the location \(\vec{r}_0\) in space is defined as
其中\(\Omega\)表示整个流动域,\(G\)表示滤波函数,\(\vec{r}\)为位置向量。滤波函数决定小尺度的结构与大小,它依赖于差\(\vec{r}_0 - \vec{r}\)以及滤波宽度\(\Delta = \left(\Delta_1\,\Delta_2\,\Delta_3\right)^{1/3}\),\(\Delta_i\)为第\(i\)个空间坐标方向的滤波宽度。最常用的滤波函数有如下几种(见图7.3):
- tophat(盒式)滤波:
- 锐利傅里叶截断滤波:
- Gaussian滤波:
en
where \(\Omega\) denotes the entire flow domain, \(G\) represents the filter function, and \(\vec{r}\) is the position vector, respectively. The filter function determines the structure and size of the small scales. The filter function depends on the difference \(\vec{r}_0 - \vec{r}\) and on the filter width \(\Delta = \left(\Delta_1\,\Delta_2\,\Delta_3\right)^{1/3}\), with \(\Delta_i\) being the filter width in the \(i\)-th spatial coordinate. The following filter functions are the mostly used ones (see Fig. 7.3):
- the tophat filter:
- The sharp Fourier cut-off filter:
- The Gaussian filter:
tophat滤波和Gaussian滤波会平滑大尺度脉动以及滤波宽度以下的小尺度。截断滤波只影响截止波数以下的尺度。实际中,Gaussian滤波总是与锐利傅里叶截断配合使用。适用于单元尺寸变化的网格的滤波函数见文献[114]、[115]。en
The tophat and the Gaussian filter smooth the large-scale fluctuations as well as the small scales below the filter width. The cut-off filter affects only the scales below the cut-off wave-number. In practice, the Gaussian filter is always employed in conjunction with a sharp Fourier cut-off. Filters suitable for grids with varying cell sizes were proposed in Refs. [114], [115].
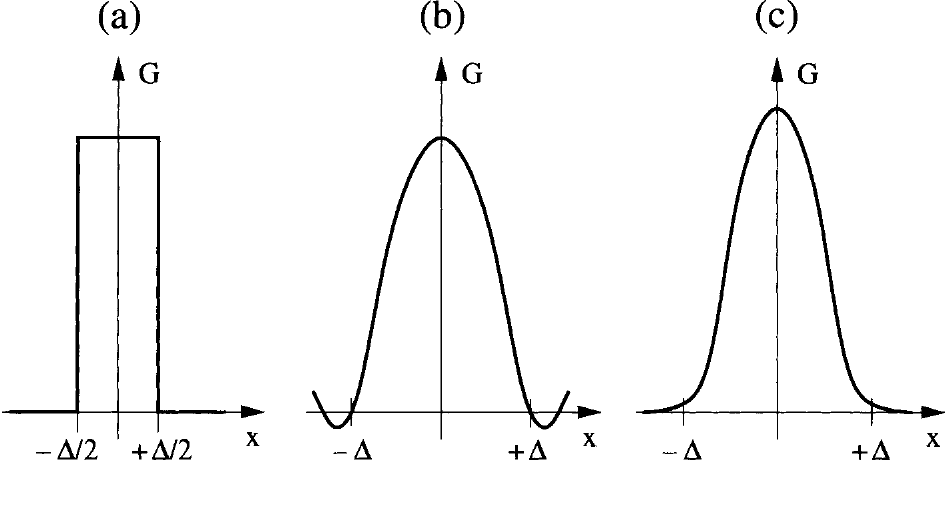
图7.3:物理空间中的LES滤波函数:tophat (a),cut-off (b),Gaussian (c)。图例:G——滤波函数;x——空间坐标;\(-\Delta/2\)、\(+\Delta/2\)——tophat滤波的支撑区间;\(-\Delta\)、\(+\Delta\)——滤波宽度标记。
7.3.2 Filtered Governing Equations 滤波控制方程[cfd-7-3-2]
为了去除小的湍流尺度,必须把由方程(7.76)和方程(7.77)定义的空间滤波作用于Navier-Stokes方程。滤波宽度\(\Delta\)和滤波函数都被视为自由参数。实际上,控制方程通常并不显式滤波,而是假定网格以及离散误差定义了滤波函数\(G\)。关于显式滤波的讨论见文献[116]、[117]。en
The spatial filtering, defined by Eq. (7.76) and Eq. (7.77), has to be applied to the Navier-Stokes equations in order to remove the small turbulent scales. The filter width \(\Delta\) as well as the filter function are considered as free parameters. In fact, the governing equations are usually not explicitly filtered. Instead, the grid as well as the discretisation errors are assumed to define the filter \(G\). For the discussion of explicit filtering see Refs. [116], [117].
由于处理方式不同,下文中我们将区分Navier-Stokes方程的可压缩形式(7.1)与不可压缩形式(7.6)。en
Because of the differing treatment, we shall distinguish in the following between compressible (7.1) and incompressible (7.6) formulation of the Navier-Stokes equations.
Incompressible Navier-Stokes Equations 不可压 Navier-Stokes 方程
对牛顿流体的不可压缩流动,滤波后的控制方程(7.6)取如下形式en
For an incompressible flow of a Newtonian fluid, the filtered governing equations (7.6) take the form
其中\(\nu\)表示运动黏度系数。方程(7.81)描述了承载能量的大尺度运动的时空演化。对流项的非线性导致出现所谓的亚网格尺度应力(subgrid-scale stress,SGS)张量en
where \(\nu\) denotes the kinematic viscosity coefficient. The equations (7.81) describe the temporal and spatial evolution of the large, energy-carrying scales of motion. The non-linearity of the convective term leads to the appearance of the so-called subgrid-scale stress (SGS) tensor
它描述不可解析尺度的影响。为了使方程封闭,必须对SGS张量建模(见小节7.3.3)。en
which describes the effects of the unresolved scales. The SGS tensor has to be modelled (see Subsection 7.3.3) in order to close the equations.
SGS张量可以分解为三个部分[118],即en
The SGS tensor can be decomposed into three parts [118], namely
各部分的物理含义如下:en
The individual parts have the following physical meaning:
为所谓的Leonard应力(Leonard stress)项,它代表产生小尺度湍流的大涡之间的相互作用。只有这一项可以由滤波速度场\(v_i\)显式求出。其次,交叉应力(cross-stress)项en
is the so-called Leonard stress term and represents the interactions between large-scale eddies which produce small-scale turbulence. This term only can be evaluated explicitly from the filtered velocity field \(v_i\). Further, the cross-stress term
描述大涡与小涡之间的相互作用。最后,en
describes interactions between large- and small-scale eddies. Finally,
为所谓的SGS雷诺应力(SGS Reynolds-stress)张量,它反映小尺度结构之间的相互作用。上述分解(7.83)如今已不再使用,主要原因是\(L_{ij}\)和\(C_{ij}\)在伽利略变换¹下不具有不变性。en
is the so-called SGS Reynolds-stress tensor. It reflects interactions between the small-scale structures. The above decomposition (7.83) is no longer used mainly because \(L_{ij}\) and \(C_{ij}\) are not invariant with respect to Galilean transformation¹.
¹原书脚注:Galilean invariance means that all frames of reference which are translating uniformly with respect to each other are equivalent.(伽利略不变性指的是,彼此做匀速平移的所有参考系都是等价的。)
Compressible Navier-Stokes Equations 可压缩 Navier-Stokes 方程
若要将LES应用于可压缩流动,就必须在对方程(7.1)做空间滤波的同时施加Favre平均(小节7.1.2)。否则,滤波后的Navier-Stokes方程将包含密度与速度、温度等其他变量的乘积。于是,式(7.1)中的速度分量、能量和温度按如下方式分解en
If LES is to be applied to compressible flows, we have to apply Favre averaging (Subsection 7.1.2) together with the spatial filtering to the Equations (7.1). Otherwise, the filtered Navier-Stokes equations would contain products between density and other variables like velocity or temperature. Thus, the velocity components, the energy and the temperature in Eq. (7.1) is decomposed as
空间中\(\vec{r}_0\)处的Favre滤波变量由下式给出en
The filtered variable at the location \(\vec{r}_0\) in space is given by
其中的各项为en
with the terms
以及en
and
在上述方程(7.89)-(7.90)中,\(e\)表示单位质量的内能,\(\tilde{S}_{ij}\)是Favre滤波应变率张量,\(\tau_{ij}^{SF} = \overline{\rho}\left(\widetilde{v_i v_j} - \tilde{v}_i\tilde{v}_j\right)\)表示Favre平均的亚网格尺度应力。此外,\(\mu\)、\(\mu_B\)和\(k\)分别表示分子黏度、体积黏度和热导率;而\(\tilde{\mu}\)、\(\tilde{\mu}_B\)和\(\tilde{k}\)是它们在滤波温度\(\tilde{T}\)下的对应取值。en
In the above equations (7.89)-(7.90), \(e\) denotes internal energy per unit mass, \(\tilde{S}_{ij}\) is the Favre-filtered strain-rate tensor, and \(\tau_{ij}^{SF} = \overline{\rho}\left(\widetilde{v_i v_j} - \tilde{v}_i\tilde{v}_j\right)\) represents the Favre-averaged subgrid-scale stress. Furthermore, \(\mu\), \(\mu_B\), and \(k\) stand for the molecular viscosity, the bulk viscosity, and for the thermal conductivity, respectively. Finally, \(\tilde{\mu}\), \(\tilde{\mu}_B\), and \(\tilde{k}\) are the corresponding values at the filtered temperature \(\tilde{T}\).
方程(7.89)的右端含有必须建模的项。在动量方程中,SGS应力\(\tau_{ij}^{SF}\)被近似,而第二项即\(\left(\overline{\sigma}_{ij} - \hat{\sigma}_{ij}\right)\)通常被忽略。在能量方程中,项\(\mathcal{A}\)可以通过SGS应力表达[119],项\(\mathcal{B}\)可以忽略,项\(\mathcal{C}\)、\(\mathcal{D}\)可按文献[120]所建议的方式建模。en
The right-hand side of Eq. (7.89) contains terms which have to be modelled. In the momentum equation, the SGS stresses \(\tau_{ij}^{SF}\) are approximated, but the second term, i.e., \(\left(\overline{\sigma}_{ij} - \hat{\sigma}_{ij}\right)\) is usually neglected. In the energy equation, term \(\mathcal{A}\) can be expressed through the SGS stresses [119], term \(\mathcal{B}\) can be neglected, and terms \(\mathcal{C}\), \(\mathcal{D}\) can be modelled as proposed in [120].
7.3.3 Subgrid-Scale Modelling 亚网格尺度建模[cfd-7-3-3]
亚网格尺度(subgrid-scale)模型的主要任务是模拟大尺度与亚网格尺度之间的能量传递。平均而言,能量从大尺度输运到小尺度(湍流串级过程)。因此,亚网格尺度模型必须提供充分的能量耗散手段。但在某些情形下,能量也会从小尺度流向大尺度——这一过程称为反向散射(backscatter)。因此模型也应当考虑这一效应。反向散射模型可参见例如[121]。en
The main task of a subgrid-scale model is to simulate energy transfer between the large and the subgrid scales. On the average, the energy is transported from the large scales to the small ones (turbulent cascade process). Therefore, a subgrid-scale model has to provide means of adequate energy dissipation. However, in some instances the energy also flows from small to large scales - a process called backscatter. Thus, the model should account for this effect as well. Backscatter models are discussed, e.g., in [121].
过去已提出多种亚网格尺度模型,研究至今仍在继续。这些模型可分为两大类。第一类是显式地建模SGS张量\(\tau_{ij}^S\)的方法,此时必要条件是空间离散格式引起的数值耗散必须远低于亚网格尺度耗散。大多数显式SGS模型基于涡黏性概念,下面将予以说明。此外,我们还将介绍构成所有亚网格尺度模型基础的Smagorinsky模型,并简要讨论所谓动力亚网格尺度(dynamic subgrid-scale)模型的基础。六种不同显式亚网格尺度模型的比较最近见于[122]。en
Various subgrid-scale models were proposed in the past and the research still continues. The models can be divided into two basic classes. The first one consists of approaches which model the SGS tensor \(\tau_{ij}^S\) explicitly. A necessary condition is then that the numerical dissipation caused by the spatial discretisation scheme must be much lower than the subgrid-scale dissipation. The majority of explicit SGS models is based on the eddy-viscosity concept, which is explained next. Furthermore, we shall present the Smagorinsky model, which forms the basis of all subgrid-scale models. We shall also briefly discuss the basics of the so-called dynamic subgrid-scale models. A comparison of six different explicit subgrid-scale models was presented recently in [122].
第二类亚网格尺度模型是通过对流通量的适当离散来隐式地模拟SGS应力(即略去\(\tau_{ij}^S\))的方法。这类模型称为单调积分大涡模拟(Monotonically Integrated LES,MILES)。该方法最早由Boris等[123]提出,近来由Grinstein和Fureby大力提倡[124]、[125]。此处的条件是数值耗散要正确地模拟亚网格尺度耗散。这并不容易做到,文献[126]和[127]的研究证明了这一点。尽管如此,MILES已在多种流动问题上取得了一定成功[128]-[134]。en
The second class of subgrid-scale models consists of approaches where the SGS stresses are modeled implicitly by an appropriate discretisation of the convective fluxes (thus \(\tau_{ij}^S\) is omitted). These models are referred to as Monotonically Integrated LES (MILES). The methodology was first presented by Boris et al. [123] and recently advocated by Grinstein and Fureby [124], [125]. The condition in this case is that the numerical dissipation correctly models the subgrid-scale dissipation. This is not quite easy to achieve, as the investigations in Ref. [126] and [127] prove. Nevertheless, MILES was applied with some success to a variety of flow problems [128]-[134].
Eddy-Viscosity Models 涡黏性模型
这些显式模型能够表现小尺度的全局耗散效应,但无法再现能量交换的局部细节。对不可压缩流动,涡黏性模型把SGS应力与大尺度应变率\(\overline{S}_{ij}\)联系起来如下en
These explicit models are able to represent the global dissipative effects of the small scales, but they cannot reproduce the local details of the energy exchange. In the case of incompressible flows, the eddy-viscosity models relate the SGS stresses to the large-scale strain-rate \(\overline{S}_{ij}\) as follows
应变率\(\overline{S}_{ij}\)由式(7.3)用滤波后的速度分量得到。为节省计算量,涡黏性\(\nu_T\)一般用代数关系式求值。SGS应力的各向同性部分(\(\tau_{kk}^S\))可以并入滤波压力[135]、单独建模[136]或忽略。en
The strain-rate \(\overline{S}_{ij}\) is obtained from Eq. (7.3) by using filtered velocity components. The eddy viscosity \(\nu_T\) is in general evaluated from algebraic relations in order to save numerical costs. The isotropic part of the SGS stresses (\(\tau_{kk}^S\)) can either be added to the filtered pressure [135], modelled [136] or neglected.
Smagorinsky SGS Model Smagorinsky SGS 模型
Smagorinsky模型[75]基于平衡假设,即小尺度把从大尺度接收到的能量全部、瞬时地耗散掉。该代数模型取如下形式en
The Smagorinsky model [75] is based on the equilibrium hypothesis which implies that the small scales dissipate entirely and instantaneously all the energy they receive from the large scales. The algebraic model assumes the form
其中\(|\overline{S}| = \left(2\overline{S}_{ij}\overline{S}_{ij}\right)^{1/2}\)为应变率张量的大小,\(C_s\)为Smagorinsky常数(Smagorinsky constant)。Lilly[137]求得的理论值为\(C_s \approx 0.18\)。但Smagorinsky常数依赖于流动类型,例如在剪切流中\(C_s\)须减小到约0.1。方程(7.93)中的滤波宽度\(\Delta\)通常取平均网格尺寸的两倍,即\(\Delta = 2\left(\Delta x_1\,\Delta x_2\,\Delta x_3\right)^{1/3}\)。en
where \(|\overline{S}| = \left(2\overline{S}_{ij}\overline{S}_{ij}\right)^{1/2}\) is the magnitude of the strain-rate tensor and \(C_s\) denotes the Smagorinsky constant. The theoretical value found by Lilly [137] is \(C_s \approx 0.18\). However, the Smagorinsky constant depends on the type of the flow. For example, in shear flows \(C_s\) has to be reduced to approximately 0.1. The filter width \(\Delta\) in Eq. (7.93) is usually chosen to be twice the average grid size, i.e., \(\Delta = 2\left(\Delta x_1\,\Delta x_2\,\Delta x_3\right)^{1/3}\).
为了体现近壁处小尺度增长的减弱,必须减小涡黏性\(\nu_T\)的取值。于是,Smagorinsky模型——方程(7.93)——按Van Driest阻尼修改为en
In order to account for the reduced growth of the small scales near walls, the value of the eddy viscosity \(\nu_T\) has to be reduced. Thus, the Smagorinsky model Eq. (7.93) is modified according to Van Driest damping as
其中\(y^{+}\)表示无量纲壁面距离(壁面距离的计算参见例如文献[39])。en
where \(y^{+}\) represents the dimensionless wall distance (for the computation of wall distances see, e.g., Ref. [39]).
Smagorinsky模型计算代价低、易于实现,但它有若干严重缺点:
- 在有平均剪切的层流区域中它耗散过强;
- 在壁面附近以及层流-湍流转捩处需要特殊处理;
- 参数\(C_s\)没有唯一定义;
- 没有模拟能量反向散射过程。
en
The Smagorinsky model is numerically cheap and easy to implement. However, it has several serious disadvantages:
- it is too dissipative in laminar regions with mean shear;
- it requires special provisions near walls and at laminar-turbulent transition;
- the parameter \(C_s\) is not uniquely defined;
- the process of energy backscatter is not modelled.
由于这些缺陷,人们提出了各种其他方法(参见例如[111])。下面这些动力模型非常流行。en
Because of these shortcomings, various other approaches were proposed (see, e.g., [111]). Very popular are the following dynamic models.
Dynamic SGS Models 动力 SGS 模型
动力SGS模型在计算方程(7.91)或(7.92)中的涡黏性\(\nu_T\)时,采用与Smagorinsky模型(方程(7.93))相同的关系式。区别在于:事先调整的Smagorinsky常数被一个在空间和时间中动态演化的参数所取代,即en
The dynamic SGS models employ the same relation as the Smagorinsky model (Eq. (7.93)) for the evaluation of the eddy viscosity \(\nu_T\) in Eq. (7.91) or (7.92). The difference is that the Smagorinsky constant (adjusted a priori) is replaced by a parameter, which evolves dynamically in space and in time. Hence,
参数\(C_d\)依据湍流最小尺度的能量含量来计算。为此,Germano等[138]提出采用第二个滤波——所谓的测试滤波(test filter)\(\hat{\Delta}\)。测试滤波的宽度必须大于作用于控制方程的滤波宽度\(\Delta\)(通常\(\hat{\Delta} = 2\Delta\))。把测试滤波作用于已滤波的方程,便得到所谓的亚测试尺度应力(subtest-scale stresses)\(\tau_{ij}^{ST}\)en
The parameter \(C_d\) is computed based on the energy content of the smallest scale of the turbulence. For this purpose, Germano et al. [138] proposed to employ a second filter - the so-called test filter \(\hat{\Delta}\). The width of the test filter has to be larger than that of the filter \(\Delta\) applied to the governing equations (usually \(\hat{\Delta} = 2\Delta\)). The application of the test filter to the filtered equations leads to the so-called subtest-scale stresses \(\tau_{ij}^{ST}\)
其中\(\hat{L}_{ij}\)表示与测试滤波相关的Leonard应力,它代表长度介于滤波宽度\(\Delta\)与测试滤波宽度\(\hat{\Delta}\)之间的尺度对雷诺应力的贡献。en
where \(\hat{L}_{ij}\) denotes the Leonard stresses associated with the test filter. It represents the contribution to the Reynolds stresses by the scales whose length is intermediate between the filter width \(\Delta\) and the test filter width \(\hat{\Delta}\).
其中en
with
记号\([\,]^{\wedge}\)表示方括号中的整个项都经过测试滤波。参数\(C_d\)可以利用Lilly的最小二乘极小化[140]从方程(7.98)导出,这给出en
The notation \([\,]^{\wedge}\) means that the whole term enclosed in the square brackets is test-filtered. The parameter \(C_d\) can be derived from Eq. (7.98) by using the least-squares minimisation of Lilly [140]. This leads to
改进的动力SGS模型由Ghosal等[141]、Carati等[142]、Piomelli和Liu[143]以及Held[90]等人提出。en
Improved dynamic SGS models were proposed, e.g., by Ghosal et al. [141], Carati et al. [142], Piomelli and Liu [143], and Held [90].
7.3.4 Wall Models 壁面模型[cfd-7-3-4]
对高雷诺数(\(Re > 10^6\))有壁流动做LES的计算代价对工程应用而言仍然过高,原因在于恰当解析壁面层需要过多的网格点(单元)。为了降低代价,可以通过指定外流速度与壁面应力之间的关联来对壁面层建模。这一做法与RANS模拟中使用壁面函数相当类似。其基本假设是近壁区与外区之间只有弱的相互作用,文献[144]和[145]的研究支持这一假设。en
The computational costs of LES of wall-bounded flows at high Reynolds numbers (\(Re > 10^6\)) are still too high for engineering purposes. The reason is the excessively large number of grid points (cells) required to resolve the wall layer appropriately. In order to reduce the costs, it is possible to model the wall layer by specifying a correlation between the velocity in the outer flow and the stress at the wall. This approach is quite similar to using wall functions in RANS simulations. The basic assumption is that there is only a weak interaction between the near-wall and the outer region, which is supported by the investigations in [144] and [145].
早期的壁面模型基于这样一种假设:壁面层的动力学是普适的,因而可以用广义壁面律来近似。这些模型基本上利用对数律(见[77]和[146]-[148])。Balaras等[149]最近提出了一种新的分区(zonal)方法。在两层模型中,滤波后的Navier-Stokes方程(7.81)一直求解到壁面上方第一个网格点;从该点到壁面之间,则在加密的嵌入网格上求解二维边界层方程。嵌入网格上的解随后用于给定壁面剪切应力,作为LES的边界条件。Balaras等[149]的分区方法允许把第一个点放在\(20 < y^{+} < 100\)的区域内,从而显著减小网格规模并缩短计算时间。该方法已成功应用于平面槽道、方形管道和旋转槽道中的湍流流动;后来又被用于分离流动的LES,结果令人鼓舞[150]-[153]。en
Earlier implementations of the wall models were based on the assumption that the dynamics of the wall layer are universal and hence they can be approximated by a generalised law-of-the-wall. Basically, the models utilised the logarithmic law (see [77] and [146]-[148]). Balaras et al. [149] proposed recently a new zonal approach. Within the two-layer model, the filtered Navier-Stokes equations (7.81) are solved up to the first grid point above the wall. From this point to the wall 2-D boundary layer equation are solved on a refined embedded grid. The solution on the embedded grid is then used to prescribe the wall shear stress as a boundary condition for the LES. The zonal approach of Balaras et al. [149] allows it to place the first point in a region \(20 < y^{+} < 100\), which leads to significantly reduced grid size and hence computational time. The methodology was applied with success to turbulent flows in a plane channel, square duct and rotating channel. Later on, it was also employed for the LES of separated flows with encouraging results [150]-[153].
7.3.5 Detached Eddy Simulation 脱体涡模拟[cfd-7-3-5]
尽管上述壁面模型有助于大幅减少网格点(单元)数量,但对于复杂的工程外形,LES仍然过于昂贵。为此,Spalart最近提出了另一种方法——所谓的脱体涡模拟(Detached Eddy Simulation,DES),其目标是高雷诺数大范围分离流动的模拟[154]、[155]。该方法可以说是RANS与LES的混合体:其思想是在强拉伸网格上配合RANS湍流模型(大多是Spalart-Allmaras模型,见小节7.2.1,或Menter的SST模型,见小节7.2.3)来解析附着边界层,而在壁面区之外配合各向同性网格使用LES来捕捉脱体的三维涡。这样,DES试图在一个统一框架内结合两种方法的长处。en
Even though the above wall models help to reduce the number of grid points (cells) considerably, LES still remains too costly for complex engineering configurations. For this reason, Spalart recently suggested another approach, the so-called Detached Eddy Simulation (DES), which is aimed at the simulation of high Reynolds-number massively separated flows [154], [155]. The methodology represents a hybrid between the RANS and LES. The idea is to employ highly stretched grids together with a RANS turbulence model (mostly the Spalart-Allmaras model from Subsection 7.2.1 or Menter's SST model from Subsection 7.2.3) to resolve the attached boundary layer(s), and to use LES outside the wall region together with an isotropic grid to capture the detached 3-D eddies. Thus, DES tries to combine the strengths of both methods in a single framework.
该长度尺度取决于控制体的最大尺寸,即\(\Delta = \max(\Delta x, \Delta y, \Delta z)\)。常数\(C_{DES}\)在一定程度上依赖于流动类型:对均匀湍流,发现\(C_{DES} = 0.65\)最优[156];而对跨声速和超声速射流,则建议取\(C_{DES} = 0.1\)[157]。方程(7.102)中长度尺度\(l\)的定义保证了:在边界层内,那里\(d < C_{DES}\Delta\)、因而\(l = d\),恢复出原始的RANS模型;而在边界层之外\(l = C_{DES}\Delta\),Spalart-Allmaras模型则充当LES的单方程SGS模型(对照方程(7.91)和式(7.24))。在时间方向积分控制方程时,全局时间步长必须调整到能够解析脱体涡的时间尺度。这通常意味着时间步长会远远超出显式格式在边界层区域的稳定裕度。因此更高效的做法是采用时间精确的隐式格式,例如6.3节所述的双时间步进方法。关于DES方法的更多细节和模拟实例可参见上述文献或[158]-[161]。en
The length scale is dependent on the largest dimension of the control volume, i.e., \(\Delta = \max(\Delta x, \Delta y, \Delta z)\). The constant \(C_{DES}\) depends to some extent on the type of the flow. For a homogeneous turbulence, the value \(C_{DES} = 0.65\) was found optimal [156]. On the other hand, \(C_{DES} = 0.1\) was recommended for transonic and supersonic jets [157]. The definition of the length scale \(l\) in Eq. (7.102) makes sure that within the boundary layer, where \(d < C_{DES}\Delta\) and hence \(l = d\), the original RANS model is recovered. On the other hand, outside the boundary layer \(l = C_{DES}\Delta\) and the Spalart-Allmaras model serves as a one-equation SGS model for the LES (cf. Eq. (7.91) and (7.24)). When integrating the governing equations in time, the global time step has to be adjusted such as to resolve the time scales of the detached eddies. This usually means that the time step would by far exceed the stability margin of an explicit scheme for the boundary layer region. It is therefore more efficient to employ a time-accurate implicit scheme, such as the dual time-stepping approach described in Section 6.3. More details regarding the DES methodology and examples of simulations can be found in the above references or in [158]-[161].